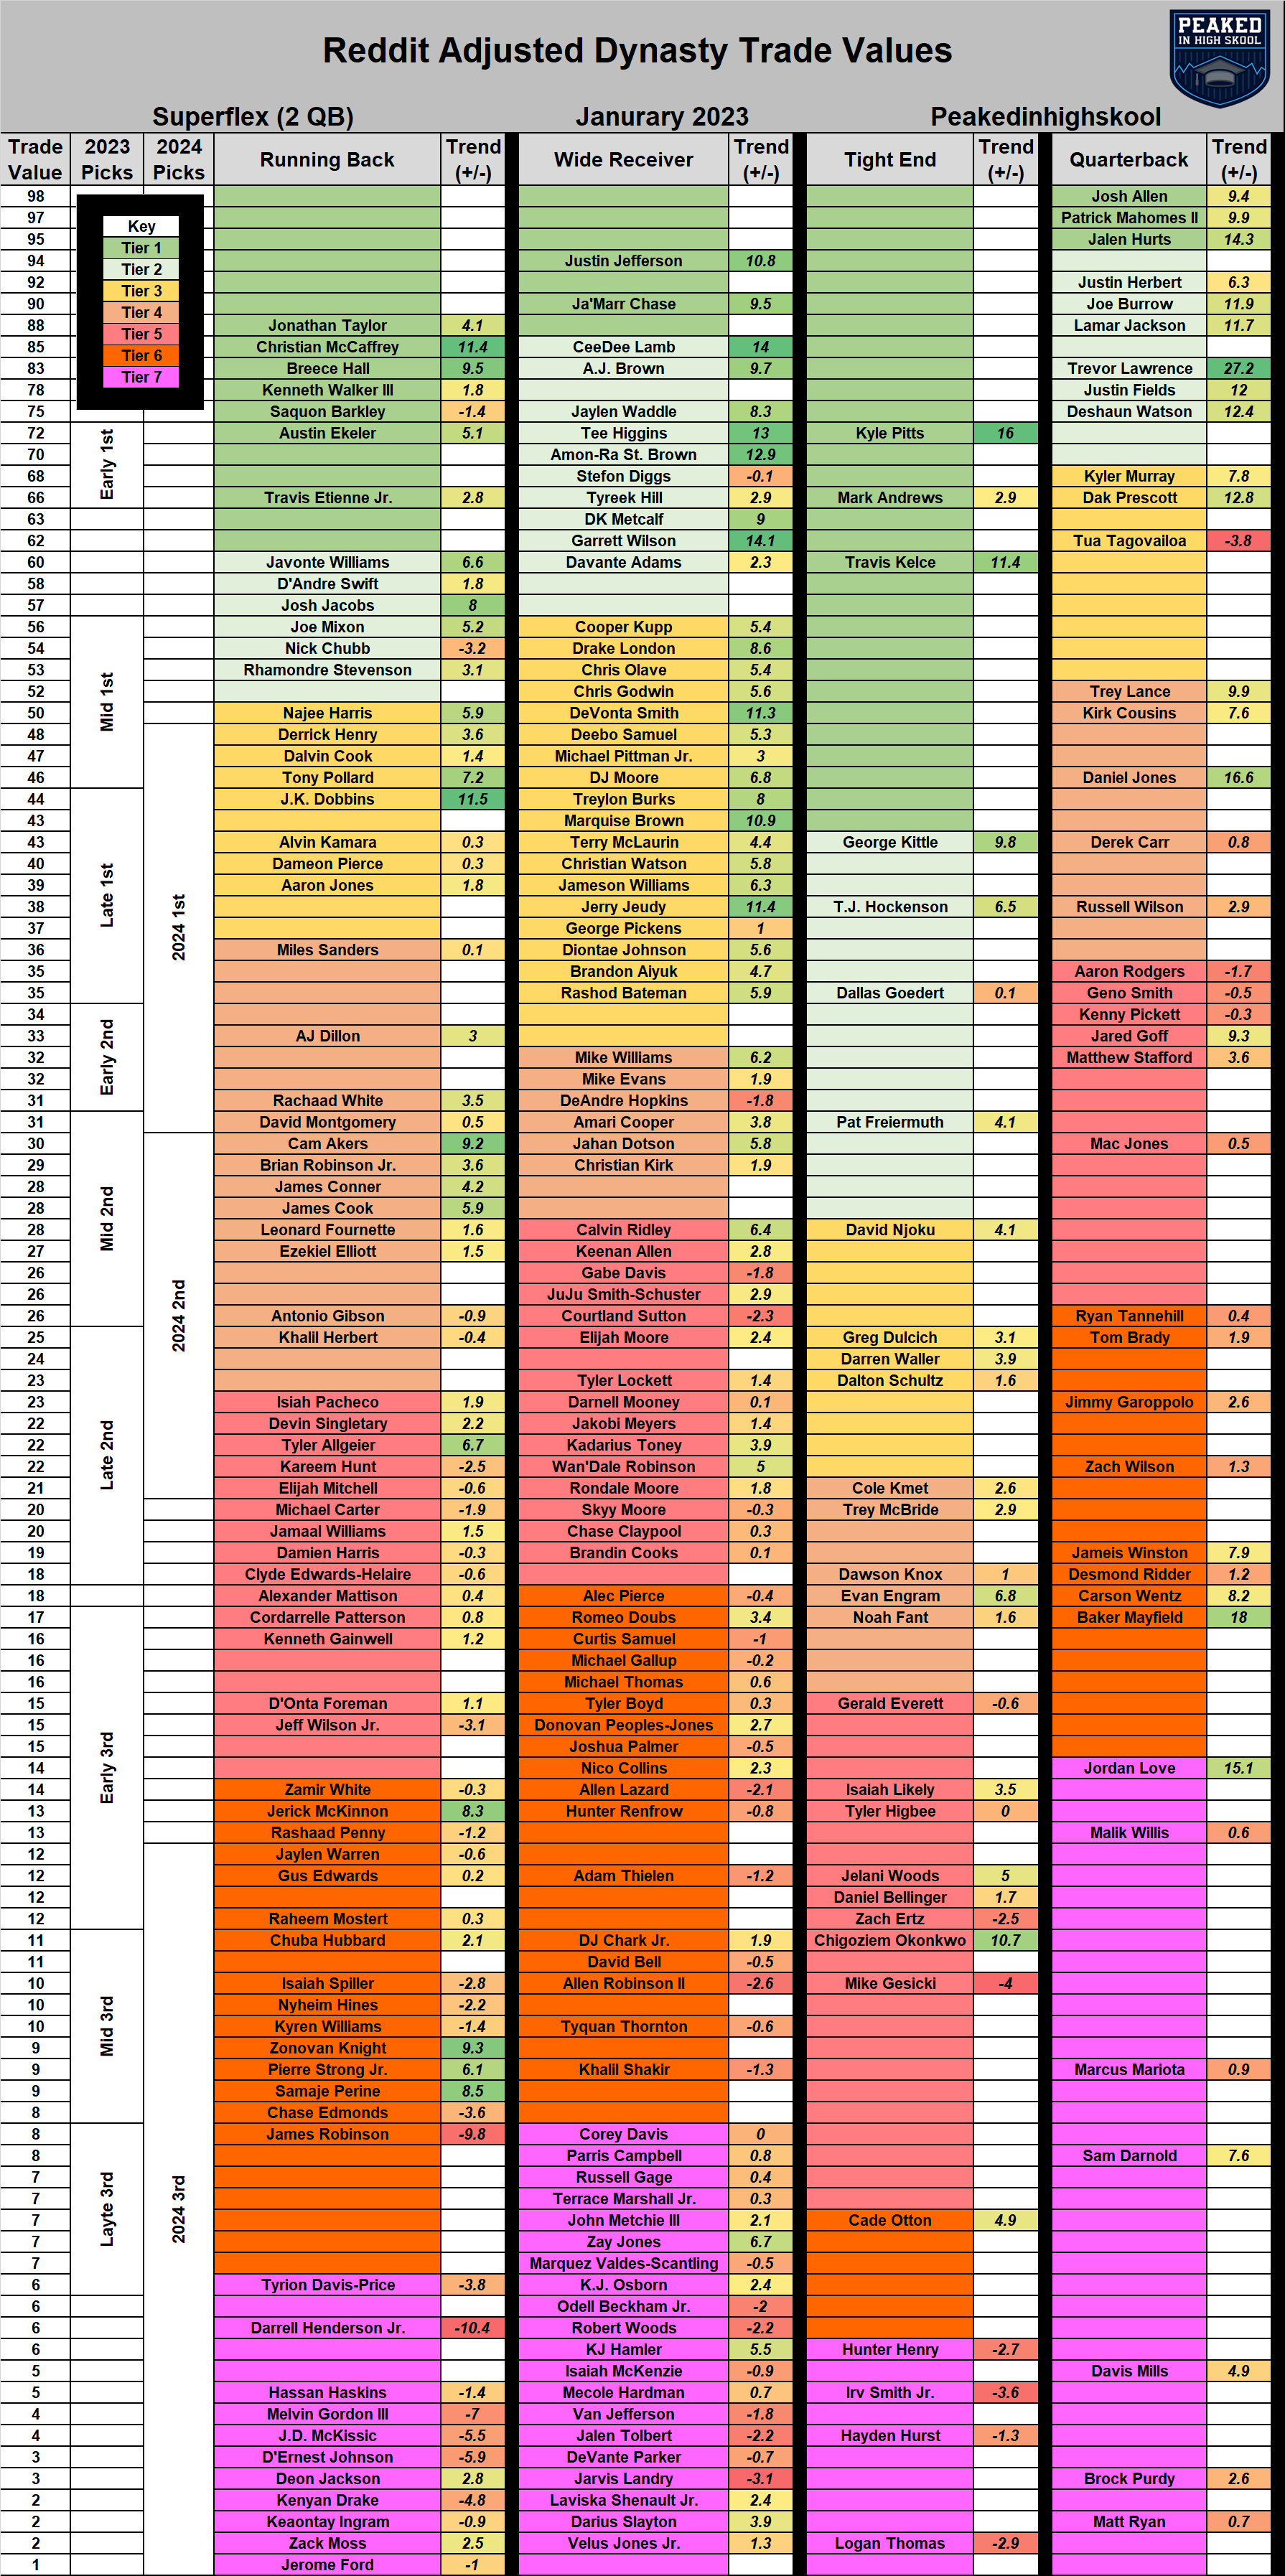
Ros Trade Value Chart
Ros Trade Value Chart - When on the step to run the examples, the c++ talker exits silently, while the python listener. Trying to use the vcs command to install ros yields this error: However your problem appears that you are trying to convert a transform into a transformstamped which isn't going to work because they are not holding the same data. If geographic_msgs provides a separate development package or sdk, be sure it has been installed. But when i use ros2 run ea maintenance mode manager maintenance mode it doesn't work, i get no executable found. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. In ros1 i would source ros again, rebuild my packages and it would be done ! The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. I have been trying to install ros 2 from binary onto windows by following these instructions. I have solved the problem of controller spawner couldn't find the expected controller_manager ros interface. by implementing hardware_interface, but now spawner. But here in ros2 dashing even when sourcing ros2 again i still have this package in those. I have been trying to install ros 2 from binary onto windows by following these instructions. However your problem appears that you are trying to convert a transform into a transformstamped which isn't going to work because they are not holding the same data. Ros2 humble hawksbill to install ros2 humble, while i'm following this : I am working on ubuntu20.04lts and using ros noetic. In ros1 i would source ros again, rebuild my packages and it would be done ! I have solved the problem of controller spawner couldn't find the expected controller_manager ros interface. by implementing hardware_interface, but now spawner. The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. When on the step to run the examples, the c++ talker exits silently, while the python listener. I have solved the problem of controller spawner couldn't find the expected controller_manager ros interface. by implementing hardware_interface, but now spawner. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. But when i use ros2 run ea maintenance mode manager maintenance mode it doesn't work, i get. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. When on the step to run the examples, the c++ talker exits silently, while the python listener. Trying to use the vcs command to install ros yields this error: I have been trying to install ros 2 from. I have been trying to install ros 2 from binary onto windows by following these instructions. In ros1 i would source ros again, rebuild my packages and it would be done ! But here in ros2 dashing even when sourcing ros2 again i still have this package in those. If geographic_msgs provides a separate development package or sdk, be sure. But here in ros2 dashing even when sourcing ros2 again i still have this package in those. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. Ros2 humble hawksbill to install ros2 humble, while i'm following this : When on the step to run the examples, the. When on the step to run the examples, the c++ talker exits silently, while the python listener. Ros2 humble hawksbill to install ros2 humble, while i'm following this : If geographic_msgs provides a separate development package or sdk, be sure it has been installed. But here in ros2 dashing even when sourcing ros2 again i still have this package in. If geographic_msgs provides a separate development package or sdk, be sure it has been installed. The depthimage to laserscan node is subscribing to the /image topic where i publish the depth images that were converted to the. The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. In ros1 i would source. I have been trying to install ros 2 from binary onto windows by following these instructions. In ros1 i would source ros again, rebuild my packages and it would be done ! However your problem appears that you are trying to convert a transform into a transformstamped which isn't going to work because they are not holding the same data.. I have solved the problem of controller spawner couldn't find the expected controller_manager ros interface. by implementing hardware_interface, but now spawner. Ros2 humble hawksbill to install ros2 humble, while i'm following this : In ros1 i would source ros again, rebuild my packages and it would be done ! I am working on ubuntu20.04lts and using ros noetic. When on. Ros2 humble hawksbill to install ros2 humble, while i'm following this : When on the step to run the examples, the c++ talker exits silently, while the python listener. The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. However your problem appears that you are trying to convert a transform into. In ros1 i would source ros again, rebuild my packages and it would be done ! If geographic_msgs provides a separate development package or sdk, be sure it has been installed. I am working on ubuntu20.04lts and using ros noetic. The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. Trying to. Ros2 humble hawksbill to install ros2 humble, while i'm following this : But when i use ros2 run ea maintenance mode manager maintenance mode it doesn't work, i get no executable found. Trying to use the vcs command to install ros yields this error: I am working on ubuntu20.04lts and using ros noetic. If geographic_msgs provides a separate development package or sdk, be sure it has been installed. The term 'vcs' is not recognized as the name of a cmdlet, function, script file, or operable program. I have solved the problem of controller spawner couldn't find the expected controller_manager ros interface. by implementing hardware_interface, but now spawner. I have been trying to install ros 2 from binary onto windows by following these instructions. In ros1 i would source ros again, rebuild my packages and it would be done ! However your problem appears that you are trying to convert a transform into a transformstamped which isn't going to work because they are not holding the same data.
ROS Stock Price and Chart — TSXVROS — TradingView

ROS Stock Price and Chart — TSXVROS — TradingView

[Boone] Week 14 ROS Rankings / Trade Value Chart r/fantasyfootball
Week 8 Trade Value Chart, Targets, and ROS Rankings (Fantasy Football 2024) 4for4
Fantasy football Week 3 Updated trade value chart, ROS rankings Yahoo Sports

ROS Stock Price and Chart — TSXVROS — TradingView
.jpg?itok=6B-eL8Qt×tamp=1728488608)
Week 6 Trade Value Chart, Targets, and ROS Rankings (Fantasy Football 2024) 4for4
Stock Market Scanning, Online Video Training for Traders and Technical Analysis of Stocks at
Week 5 Trade Value Chart, Targets, and ROS Rankings (Fantasy Football 2024) 4for4
Alex PeakedInHighSkool on Twitter "The January edition of the Dynasty Superflex Trade Value
But Here In Ros2 Dashing Even When Sourcing Ros2 Again I Still Have This Package In Those.
When On The Step To Run The Examples, The C++ Talker Exits Silently, While The Python Listener.
The Depthimage To Laserscan Node Is Subscribing To The /Image Topic Where I Publish The Depth Images That Were Converted To The.
Related Post: