Euler's Method Chart
Euler's Method Chart - Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? I know why euler angles suffer from gimbal lock (with the help of a physical gimbal/gyro model), but i read from various sources (1,2) that rotation matrices do not. The difference is that the. I don't expect one to know the proof of every dependent theorem of a given. I'm having a hard time understanding what is. The function ϕ(n) ϕ (n) calculates the number of positive integers k ⩽ n , gcd(k, n) = 1 k ⩽ n , gcd (k, n) = 1. It was found by mathematician leonhard euler. Euler's totient function, using the euler totient function for a large number, is there a methodical way to compute euler's phi function and euler's totient function of 18. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. Extrinsic and intrinsic euler angles to rotation matrix and back ask question asked 10 years, 1 month ago modified 9 years ago There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. I know why euler angles suffer from gimbal lock (with the help of a physical gimbal/gyro model), but i read from various sources (1,2) that rotation matrices do not. Then the two references you cited tell you how to obtain euler angles from any given. Using euler's formula in graph theory where r − e + v = 2 r e + v = 2 i can simply do induction on the edges where the base case is a single edge and the result will be 2. 1 you can find a nice simple formula for computing the rotation matrix from the two given vectors here. The function ϕ(n) ϕ (n) calculates the number of positive integers k ⩽ n , gcd(k, n) = 1 k ⩽ n , gcd (k, n) = 1. Euler's totient function, using the euler totient function for a large number, is there a methodical way to compute euler's phi function and euler's totient function of 18. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? Extrinsic and intrinsic euler angles to rotation matrix and back ask question asked 10 years, 1 month ago modified 9 years ago Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? Euler's totient function, using the euler totient function for a large number, is there a methodical way to compute euler's phi function and euler's totient function of 18. Euler's formula is quite a fundamental result, and we never know where it. Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. Extrinsic and intrinsic euler angles to rotation matrix and back ask question asked 10 years, 1 month ago modified 9 years ago I'm. I don't expect one to know the proof of every dependent theorem of a given. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. It was found by mathematician leonhard euler. 1 you can find a nice simple formula for computing the. Euler's formula is quite a fundamental result, and we never know where it could have been used. I'm having a hard time understanding what is. I don't expect one to know the proof of every dependent theorem of a given. The difference is that the. I know why euler angles suffer from gimbal lock (with the help of a physical. There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. I'm having a hard time understanding what is. Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? Euler's totient function, using the euler totient function for a large number, is there a. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. I'm having a hard time understanding what is. There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. I don't expect one to know the. 1 you can find a nice simple formula for computing the rotation matrix from the two given vectors here. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. Using euler's formula in graph theory where r − e + v = 2. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? I don't expect one to know the proof of every dependent theorem of a. Then the two references you cited tell you how to obtain euler angles from any given. There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. Euler's totient function, using the euler totient function for a large number, is there a methodical way to compute euler's phi function and euler's totient function. 1 you can find a nice simple formula for computing the rotation matrix from the two given vectors here. Euler's formula is quite a fundamental result, and we never know where it could have been used. Using euler's formula in graph theory where r − e + v = 2 r e + v = 2 i can simply do. Euler's formula is quite a fundamental result, and we never know where it could have been used. Extrinsic and intrinsic euler angles to rotation matrix and back ask question asked 10 years, 1 month ago modified 9 years ago I'm having a hard time understanding what is. Can someone show mathematically how gimbal lock happens when doing matrix rotation with euler angles for yaw, pitch, roll? The function ϕ(n) ϕ (n) calculates the number of positive integers k ⩽ n , gcd(k, n) = 1 k ⩽ n , gcd (k, n) = 1. Euler's totient function, using the euler totient function for a large number, is there a methodical way to compute euler's phi function and euler's totient function of 18. Then the two references you cited tell you how to obtain euler angles from any given. I read on a forum somewhere that the totient function can be calculated by finding the product of one less than each of the number's prime factors. There is one difference that arises in solving euler's identity for standard trigonometric functions and hyperbolic trigonometric functions. The difference is that the. I don't expect one to know the proof of every dependent theorem of a given. It was found by mathematician leonhard euler.
PPT Euler Method PowerPoint Presentation, free download ID9615073
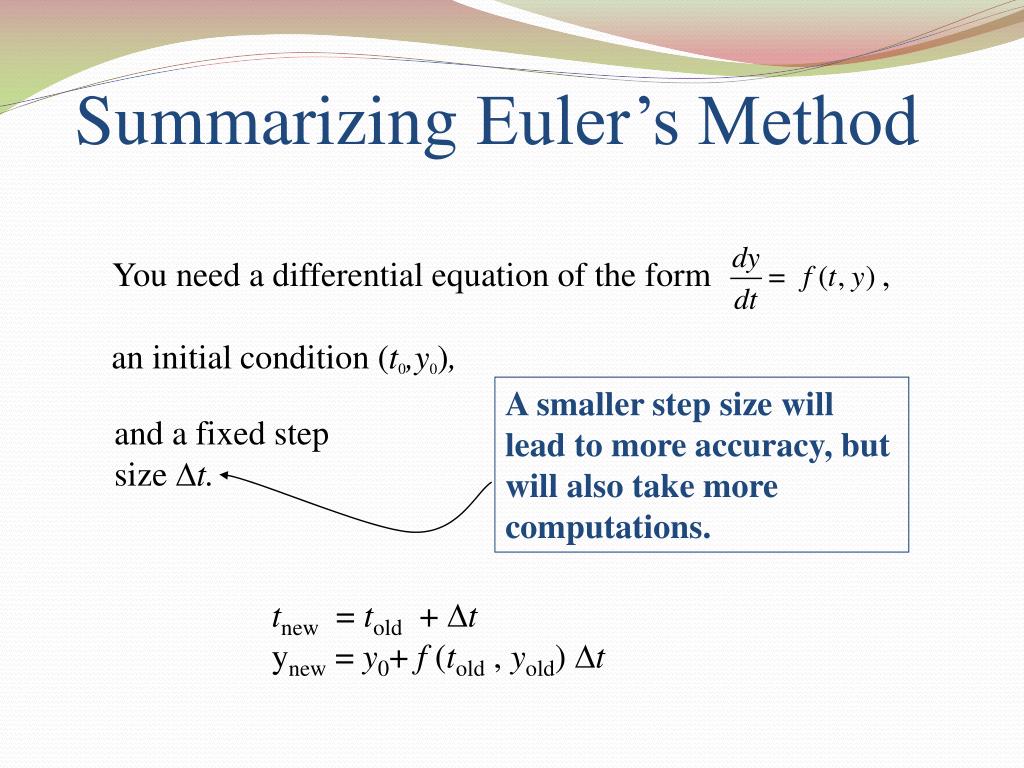
PPT Euler’s Method PowerPoint Presentation, free download ID2857517
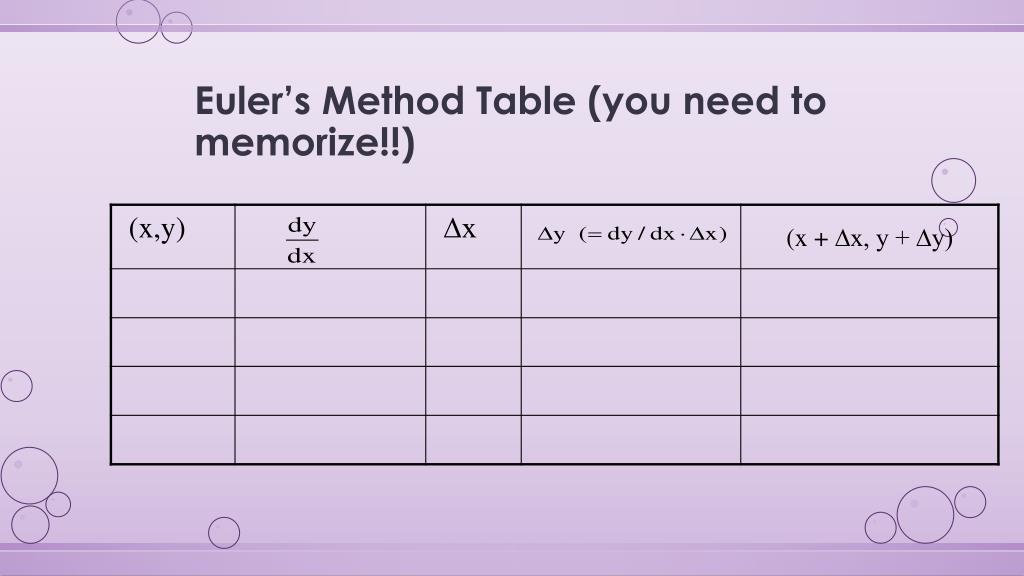
PPT 5. Euler’s Method PowerPoint Presentation, free download ID1925882

Euler's Method · Differential Equation Numerical Solution · Matter of Math
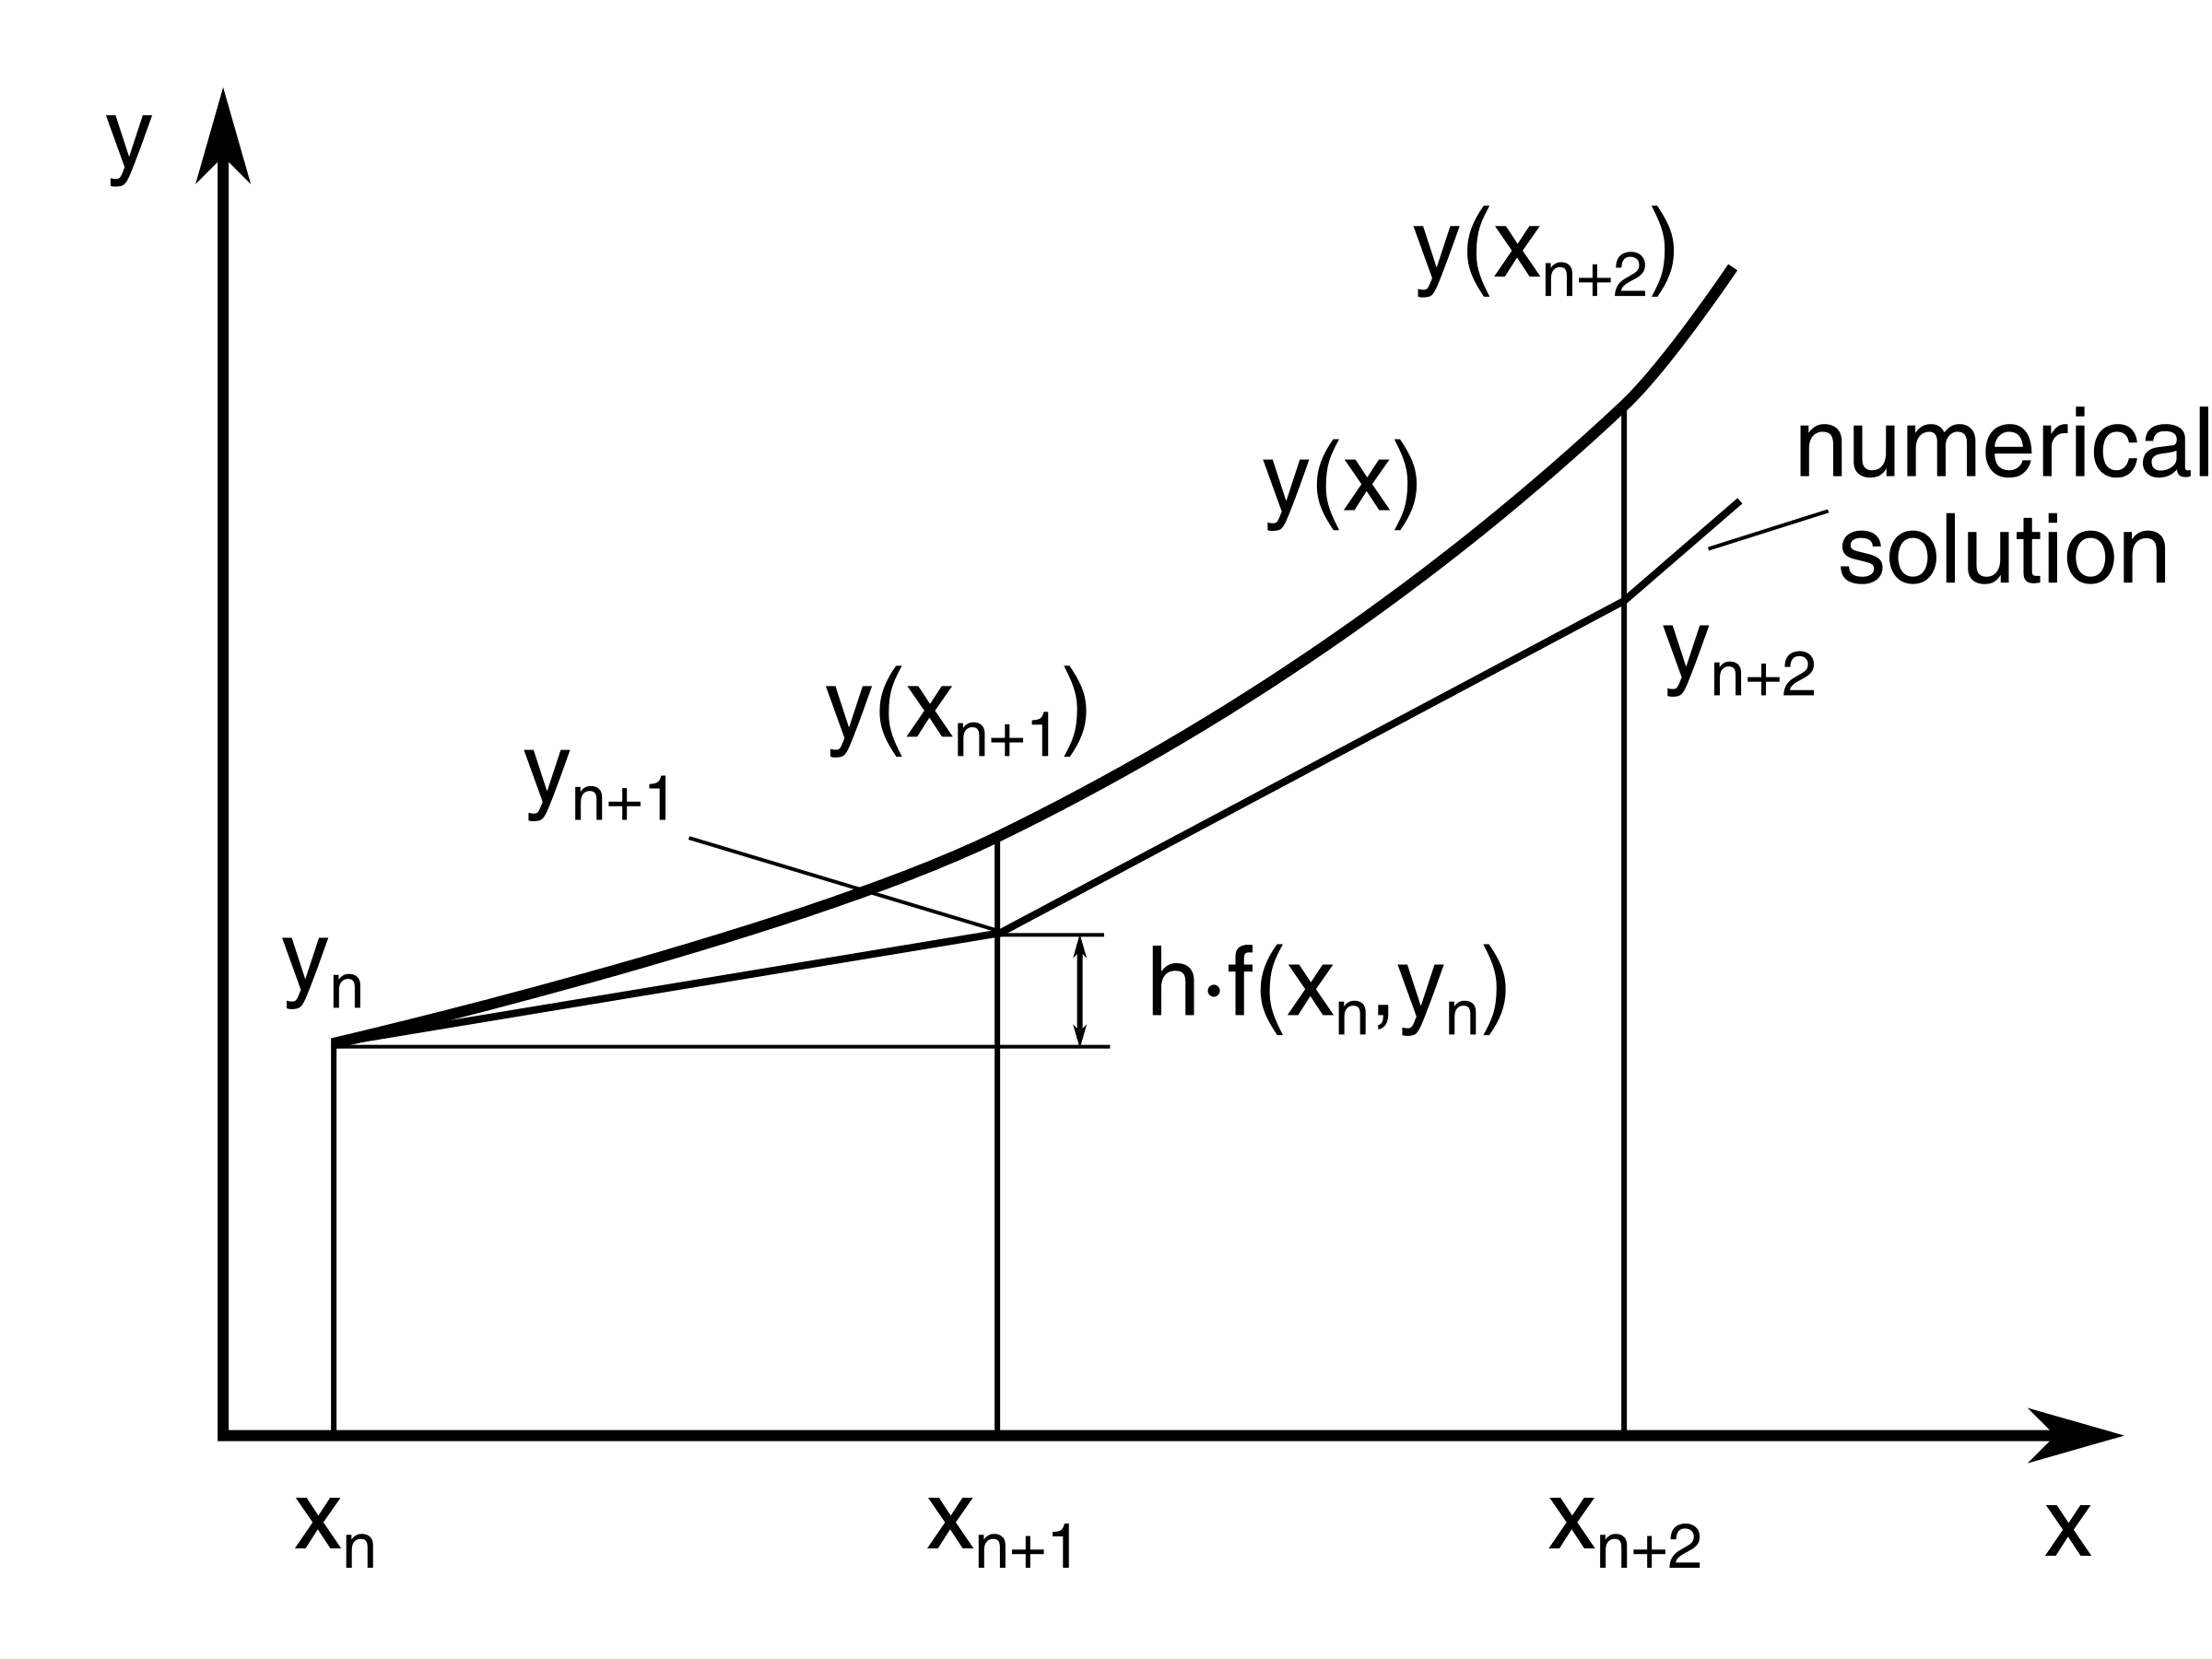
Euler's Method Explained with Examples
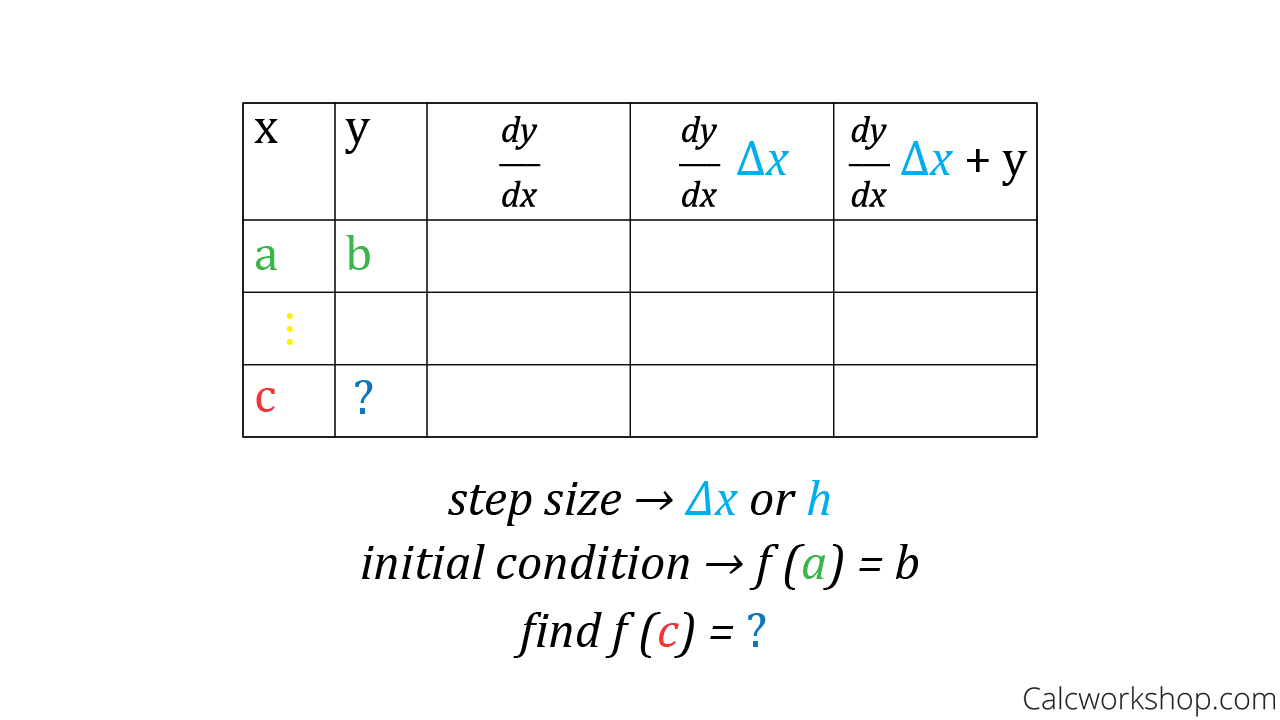
Eulers Method
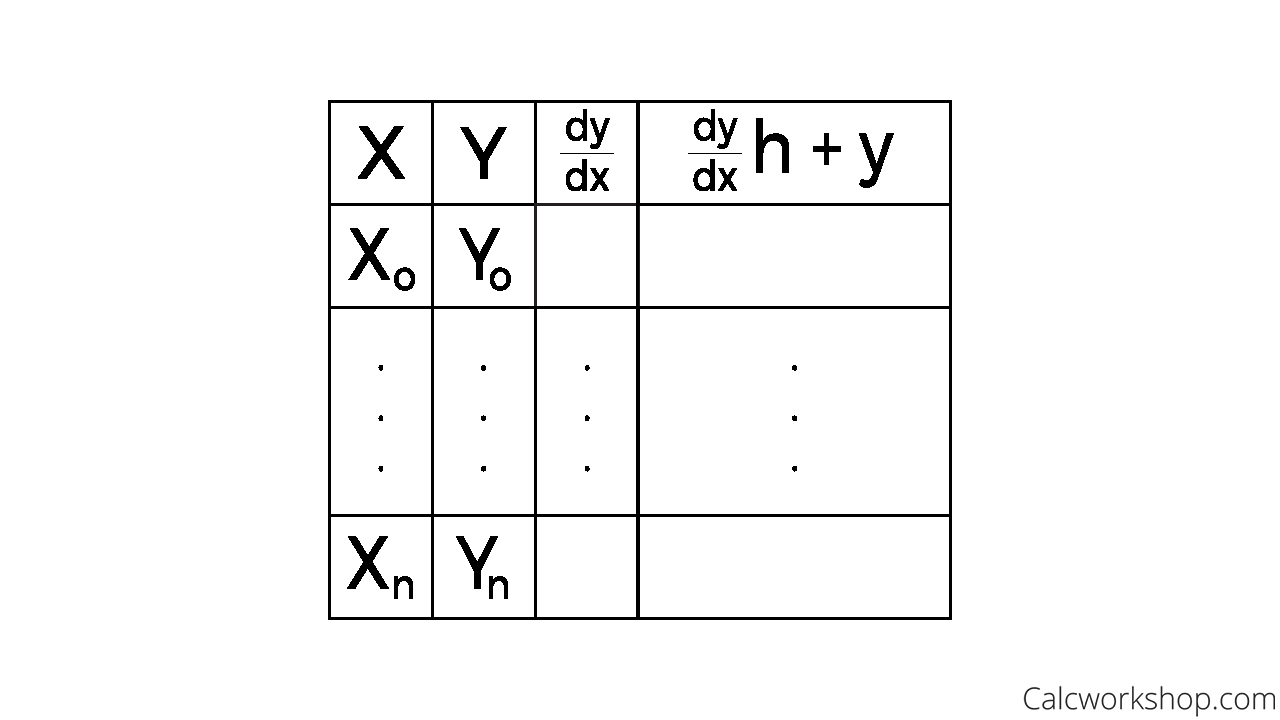
How to do Euler's Method? (Simply Explained in 4 Powerful Examples)
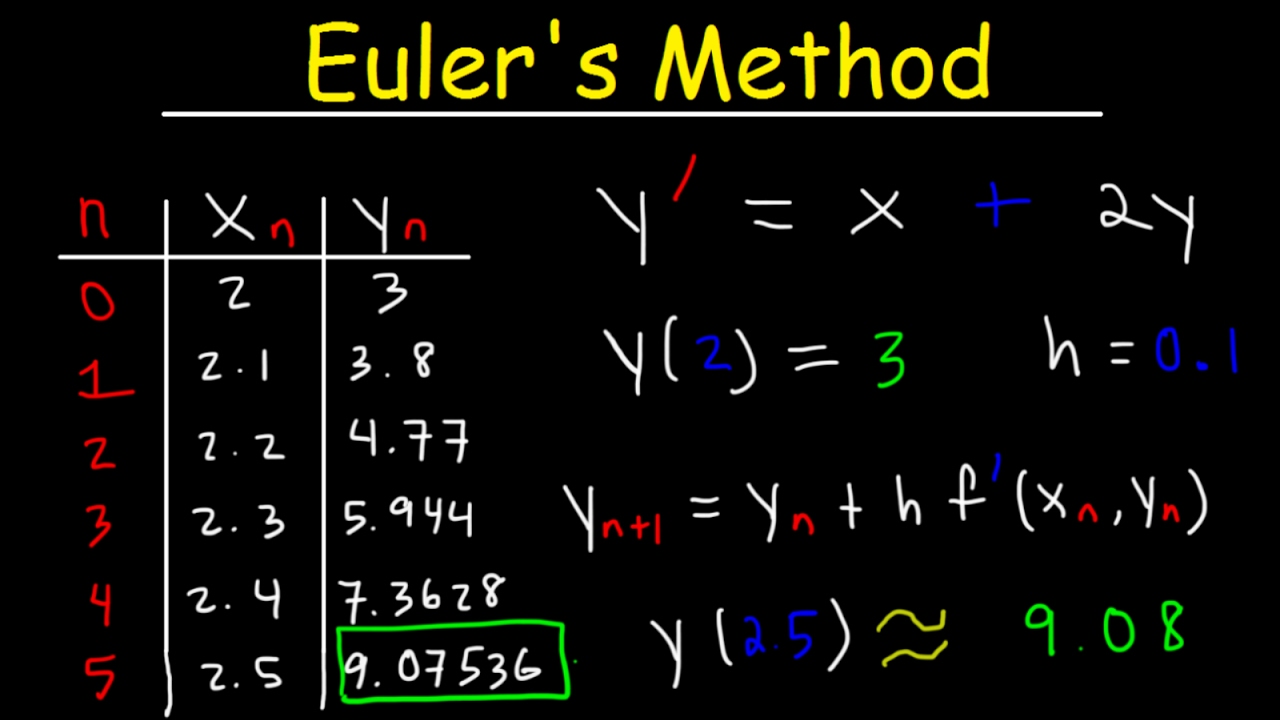
Euler's Method Differential Equations, Examples, Numerical Methods, Calculus YouTube
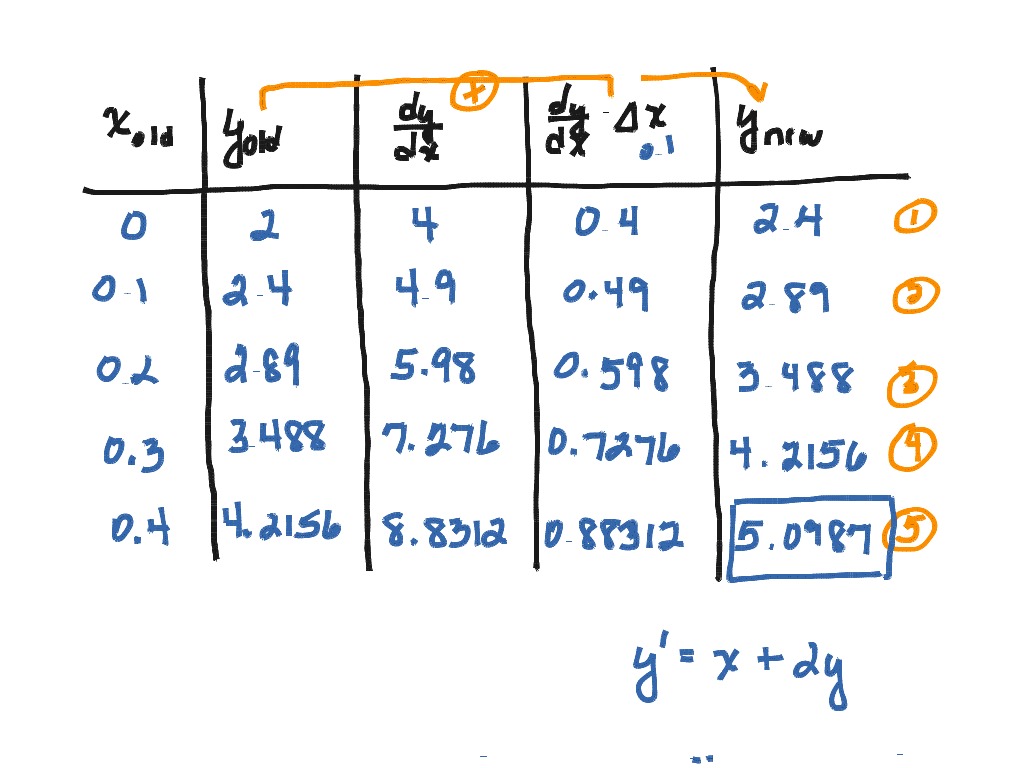
Eulers Method problem Math, Calculus, Application of Differentiation ShowMe
How to do Euler's Method? (Simply Explained in 4 Powerful Examples)
I Know Why Euler Angles Suffer From Gimbal Lock (With The Help Of A Physical Gimbal/Gyro Model), But I Read From Various Sources (1,2) That Rotation Matrices Do Not.
Using Euler's Formula In Graph Theory Where R − E + V = 2 R E + V = 2 I Can Simply Do Induction On The Edges Where The Base Case Is A Single Edge And The Result Will Be 2.
1 You Can Find A Nice Simple Formula For Computing The Rotation Matrix From The Two Given Vectors Here.
Related Post: